The Team Systèmes Robustes pour la Robotique (SyRRo) is part of UFR S2I and more precisely in laboratory U2IS on campus Paris-Saclay at ENSTA member of IP Paris.
The techniques and methods developed in SyRRo team aim at controling uncertainty in order to make systems robust and ensure their safe operation.
To achieve these goals, on the one hand, “correct-by-construction” approaches based on model-driven design or data-driven methods are developed. For example, work relying on ensemble or probabilistic methods, techniques from control theory, and methods related to reinforcement learning will continue to be advanced. On the other hand, online or a posteriori verification approaches are also developed to propose solutions for system robustification. For instance, methods based on monitoring or runtime verification techniques are defined.
These approaches apply to all algorithmic components of an autonomous robot involved in the perception, decision/planning, and action loop.
These theoretical developments are tested in the field through experiments on real-world platforms in the field of aerial and terrestrial robotics.
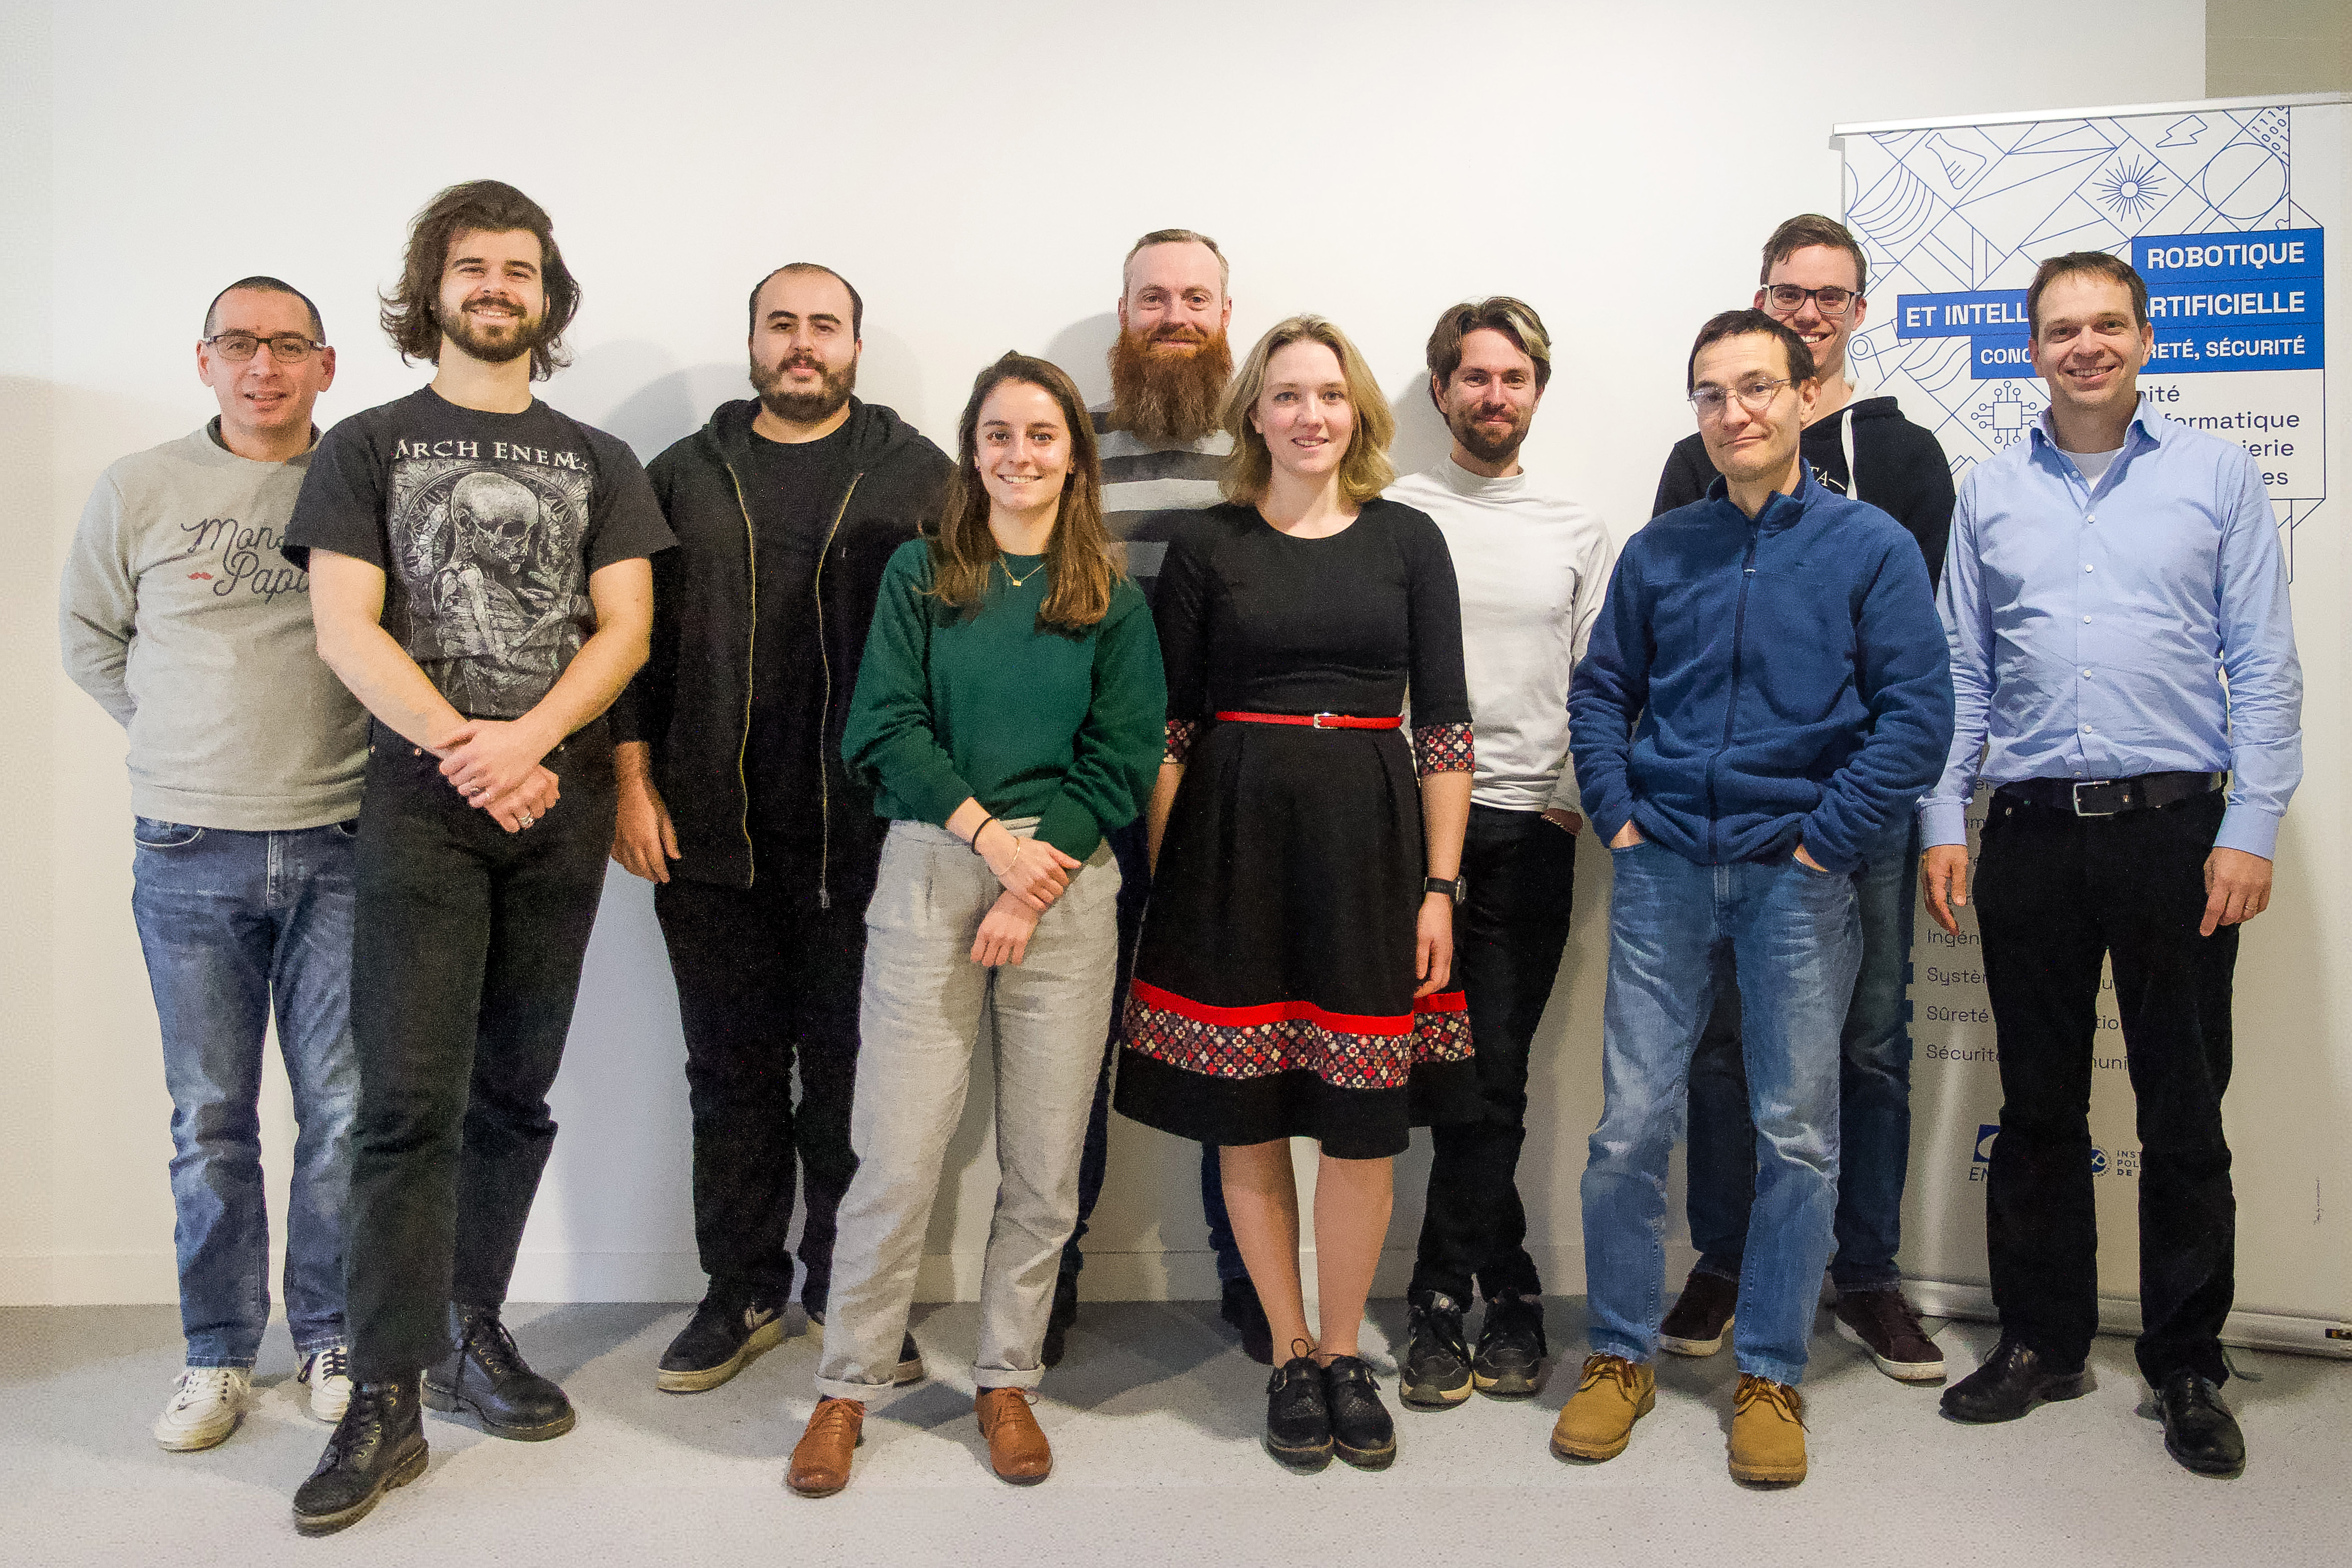
(Jan 2023) From left to right: Alexandre Chapoutot, Clément Yver, Danil Berrah, Caroline Pascal, Julien Alexandre dit Sandretto, Elena Vanneaux, Thibault toralba, François Pessaux, David Brellmann, Goran Frehse (missing on the picture Gwendal Priser).
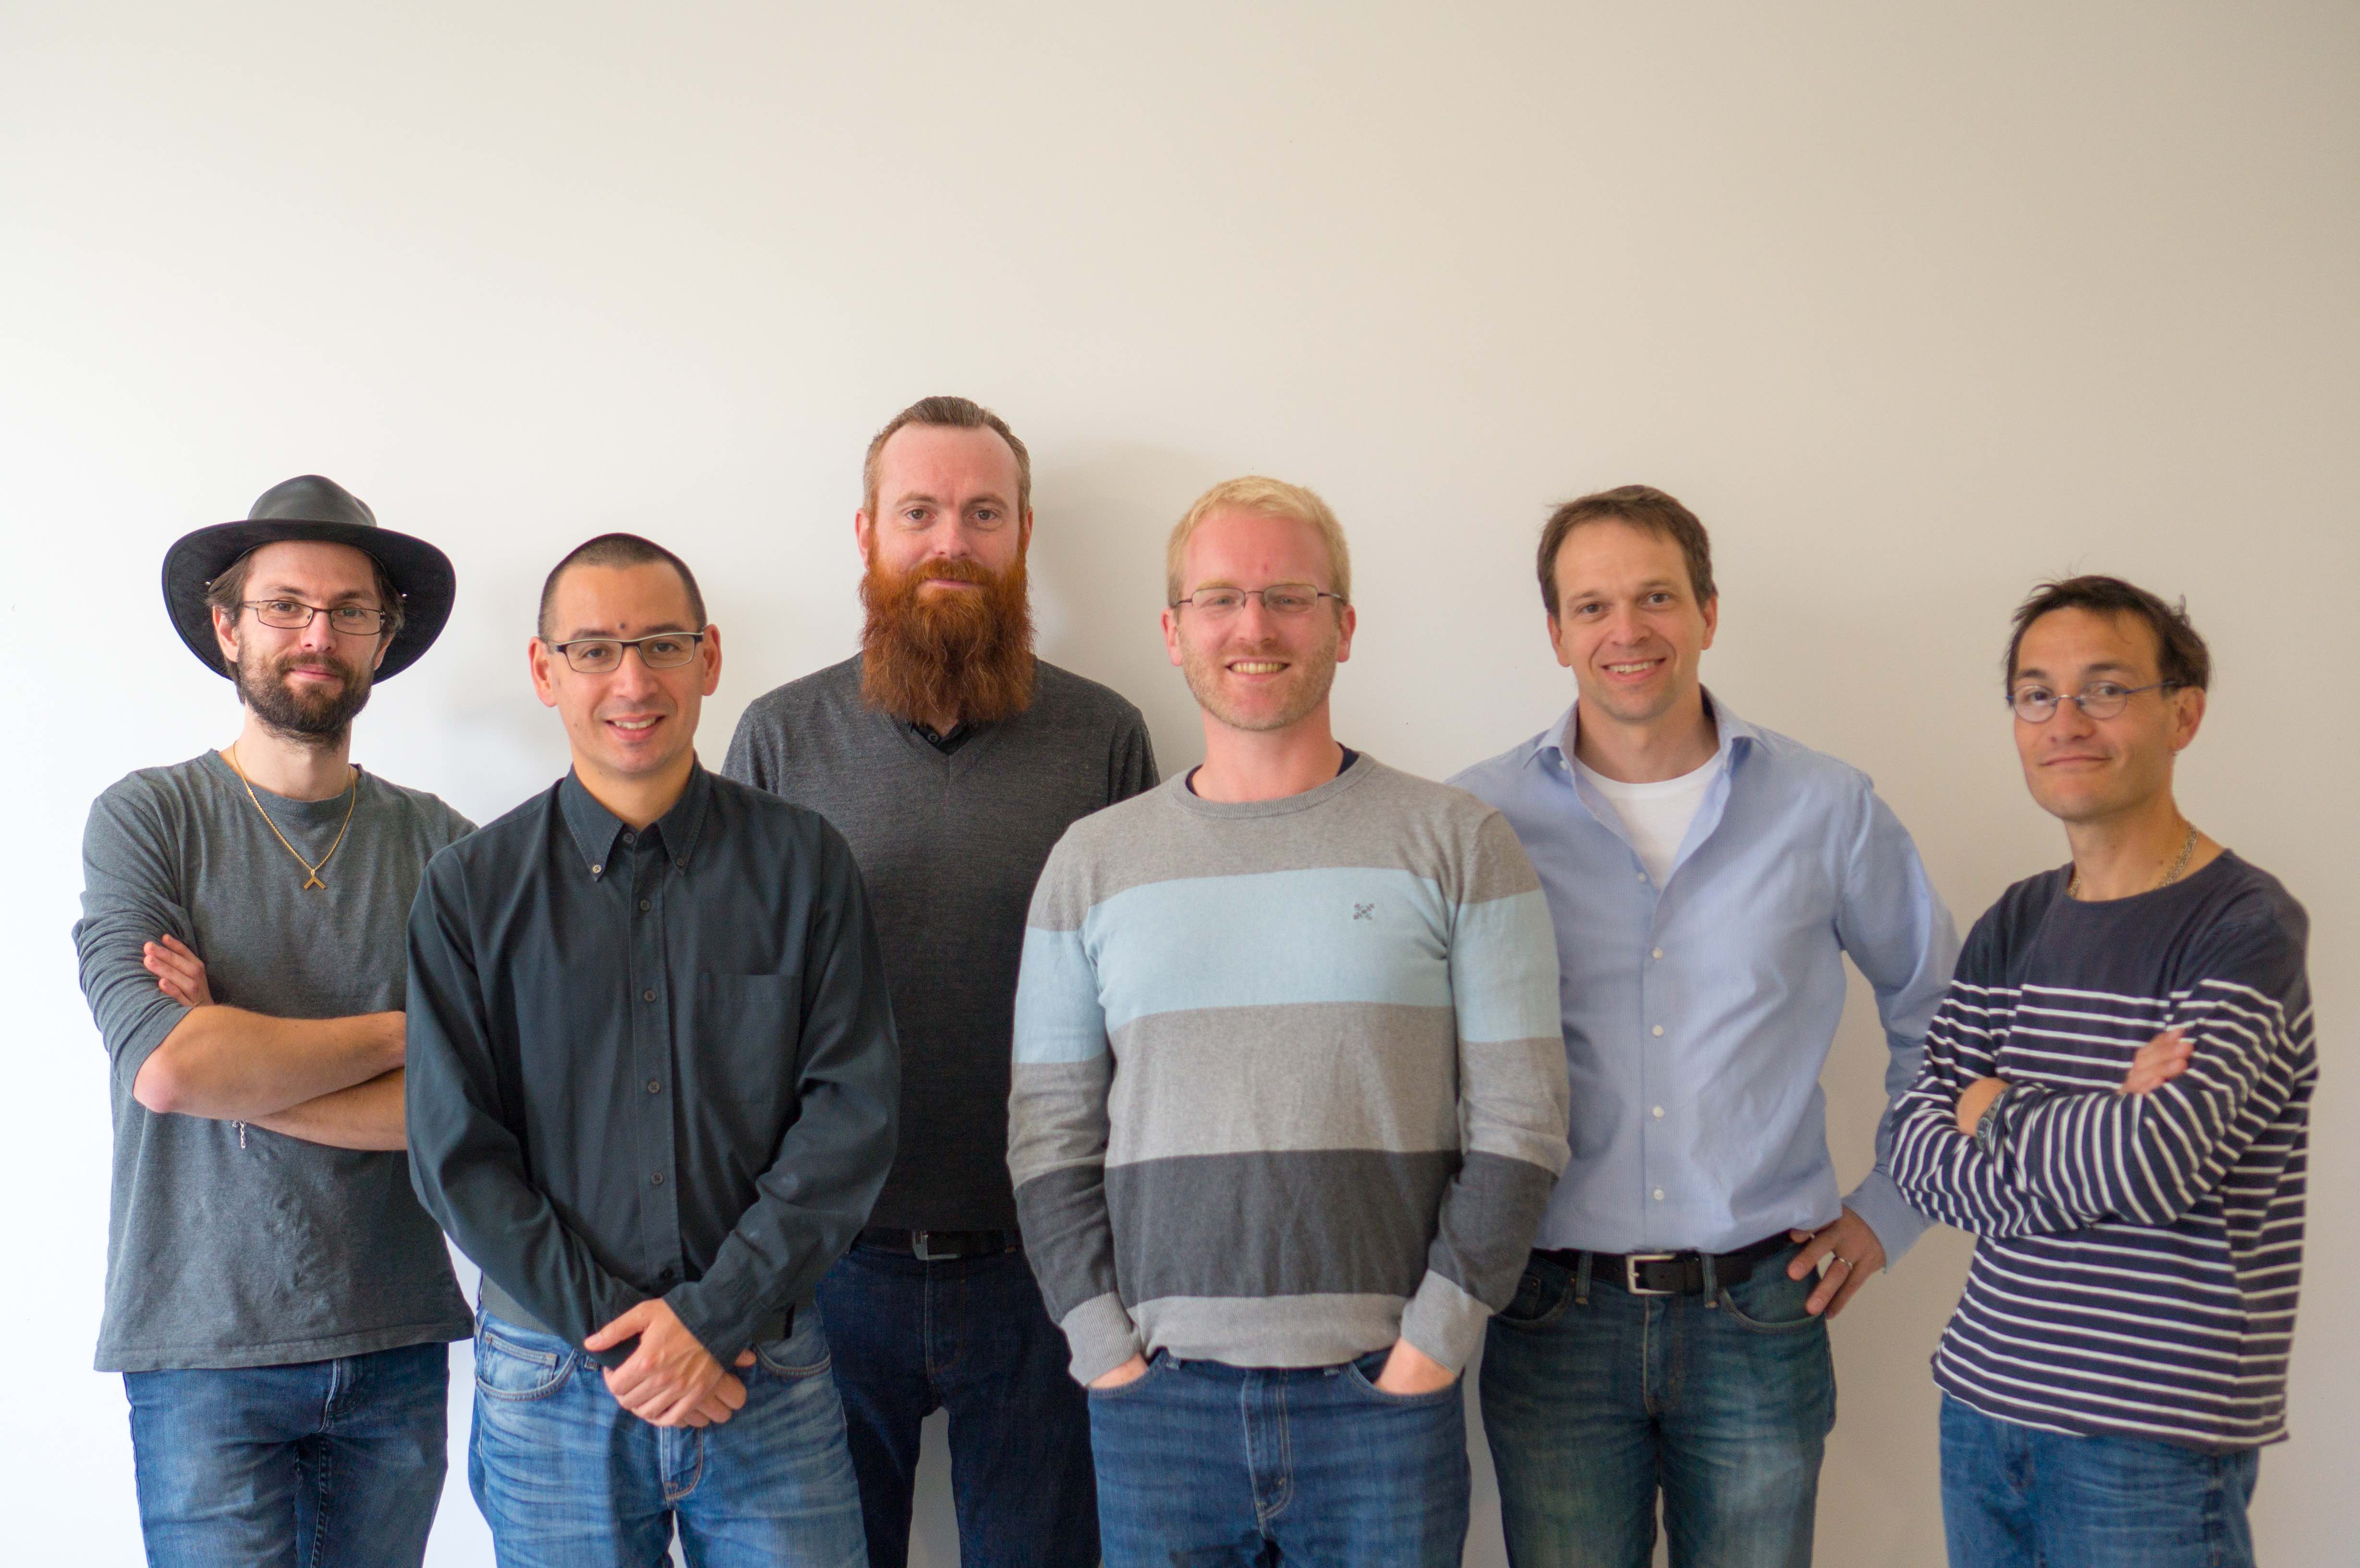
(Oct. 2018) From left to right: Thibault Toralba, Alexandre Chapoutot, Julien Alexandre dit Sandretto, Olivier Mullier, Goran Frehse, François Pessaux.